Byeong-Il Ham

MSC Lab. @ KAIST
Daejeon, Republic of Korea
received his B.S. degree in the School of Robotics from University of Kwangwoon, Seoul, and his M.S. degree in Robotics Program from Korea Advanced Institute of Science and Technology(KAIST), Daejeon, Republic of Korea, in 2022 and 2024, respectively. He is currently pursuing his Doctor Program in KAIST, Daejeon, Korea, from 2024. His current research interests include legged systems, optimal control, and motion planning.
Selected Publications
-
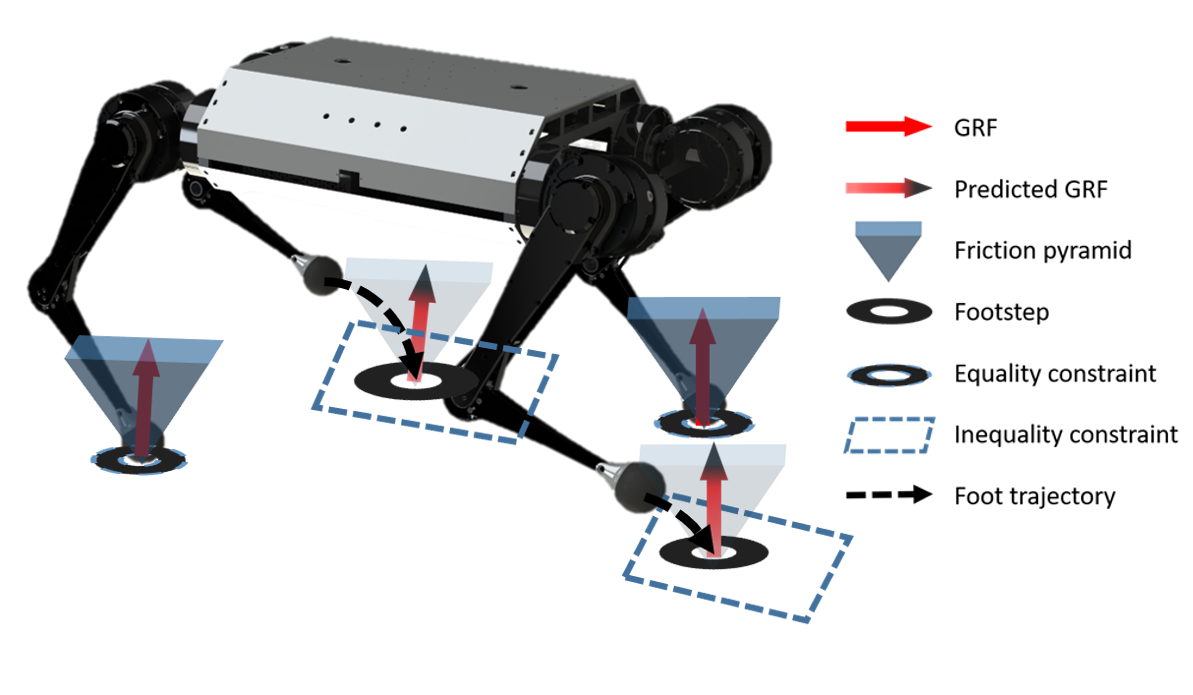 Dual-MPC Footstep Planning for Robust Quadruped LocomotionIEEE/ASME Transactions on Mechatronics, 2026
-
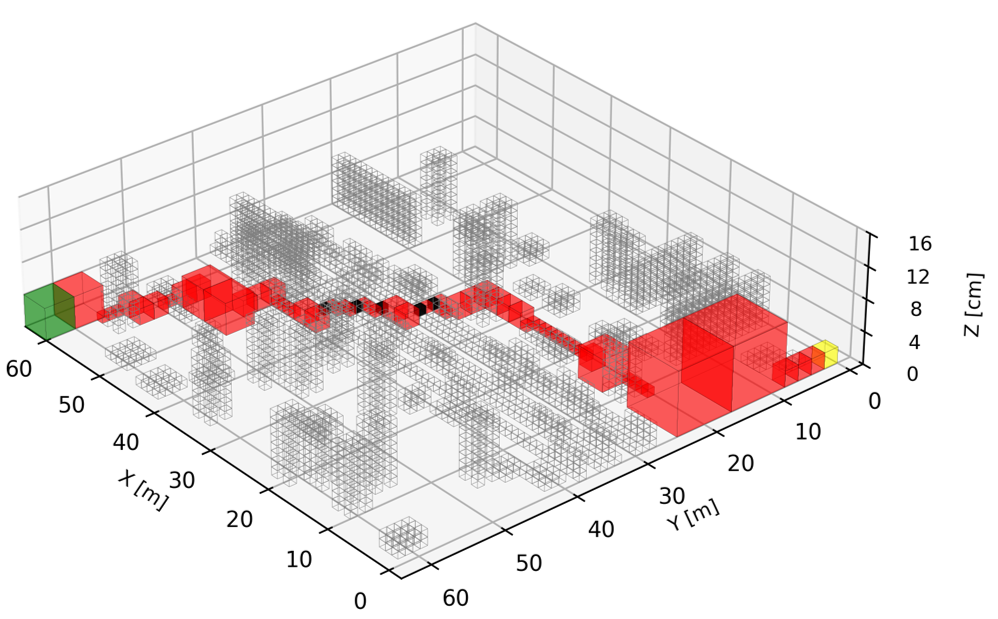 Ground-Aware Octree-A* Hybrid Path Planning for Memory-Efficient 3D Navigation of Ground VehiclesIn 2025 25th International Conference on Control, Automation and Systems (ICCAS), 2025
Selected Projects
- Nonlinear Dynamics Solver using Spectral PINN
- Manipulator Path Planning Through Diffusion Model