publications
publications by categories in reversed chronological order. generated by jekyll-scholar.
Journal Articles
2026
-
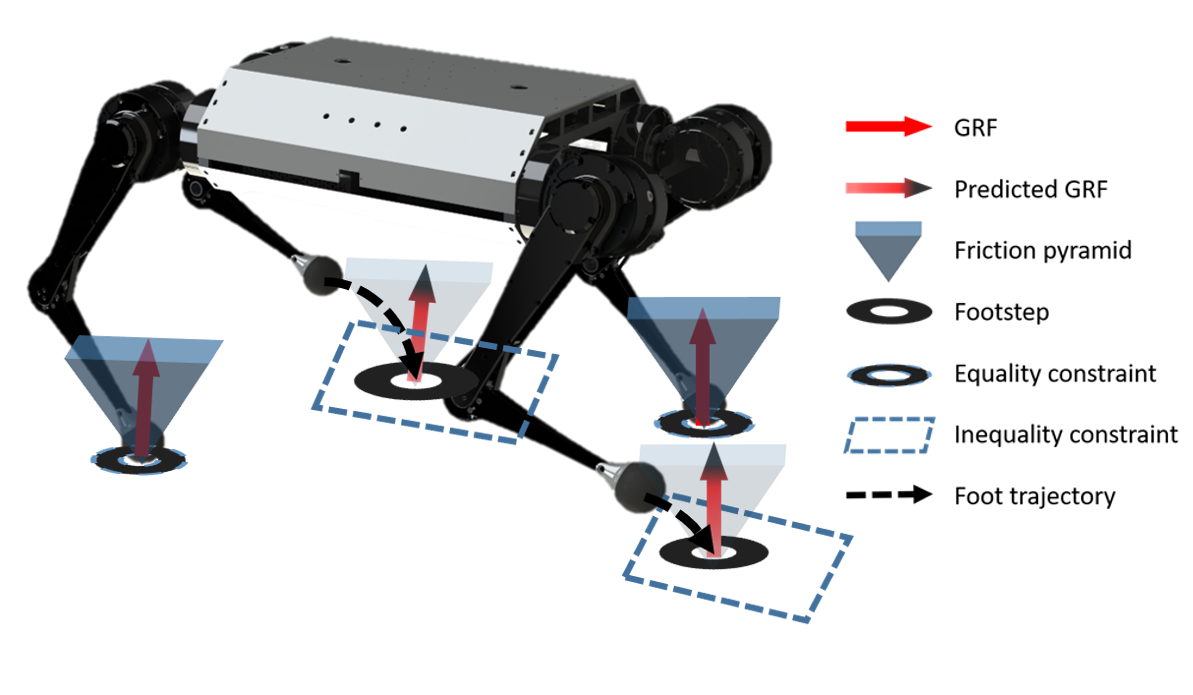 Dual-MPC Footstep Planning for Robust Quadruped LocomotionIEEE/ASME Transactions on Mechatronics, 2026
2025
- Temperature Compensation Method for a Six-Axis Force/Torque Sensor Using a Gated Recurrent UnitIEEE Sensors Journal, 2025
- Compact and optimized optical six-axis force/torque sensor for legged robotsIEEE Transactions on Instrumentation and Measurement, 2025
- A Miniature High-Resolution Tension Sensor Based on a Photo-Reflector for Robotic Hands and GrippersIEEE Sensors Journal, 2025
2024
- External force adaptive control in legged robots through footstep optimization and disturbance feedbackIEEE Access, 2024
Conference Papers
2025
-
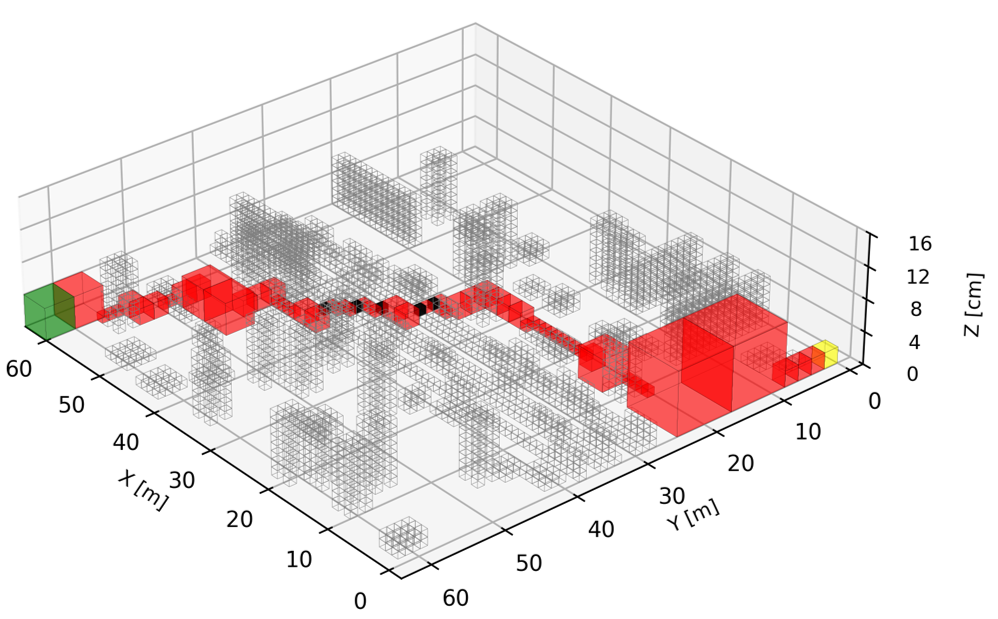 Ground-Aware Octree-A* Hybrid Path Planning for Memory-Efficient 3D Navigation of Ground VehiclesIn 2025 25th International Conference on Control, Automation and Systems (ICCAS), 2025
-
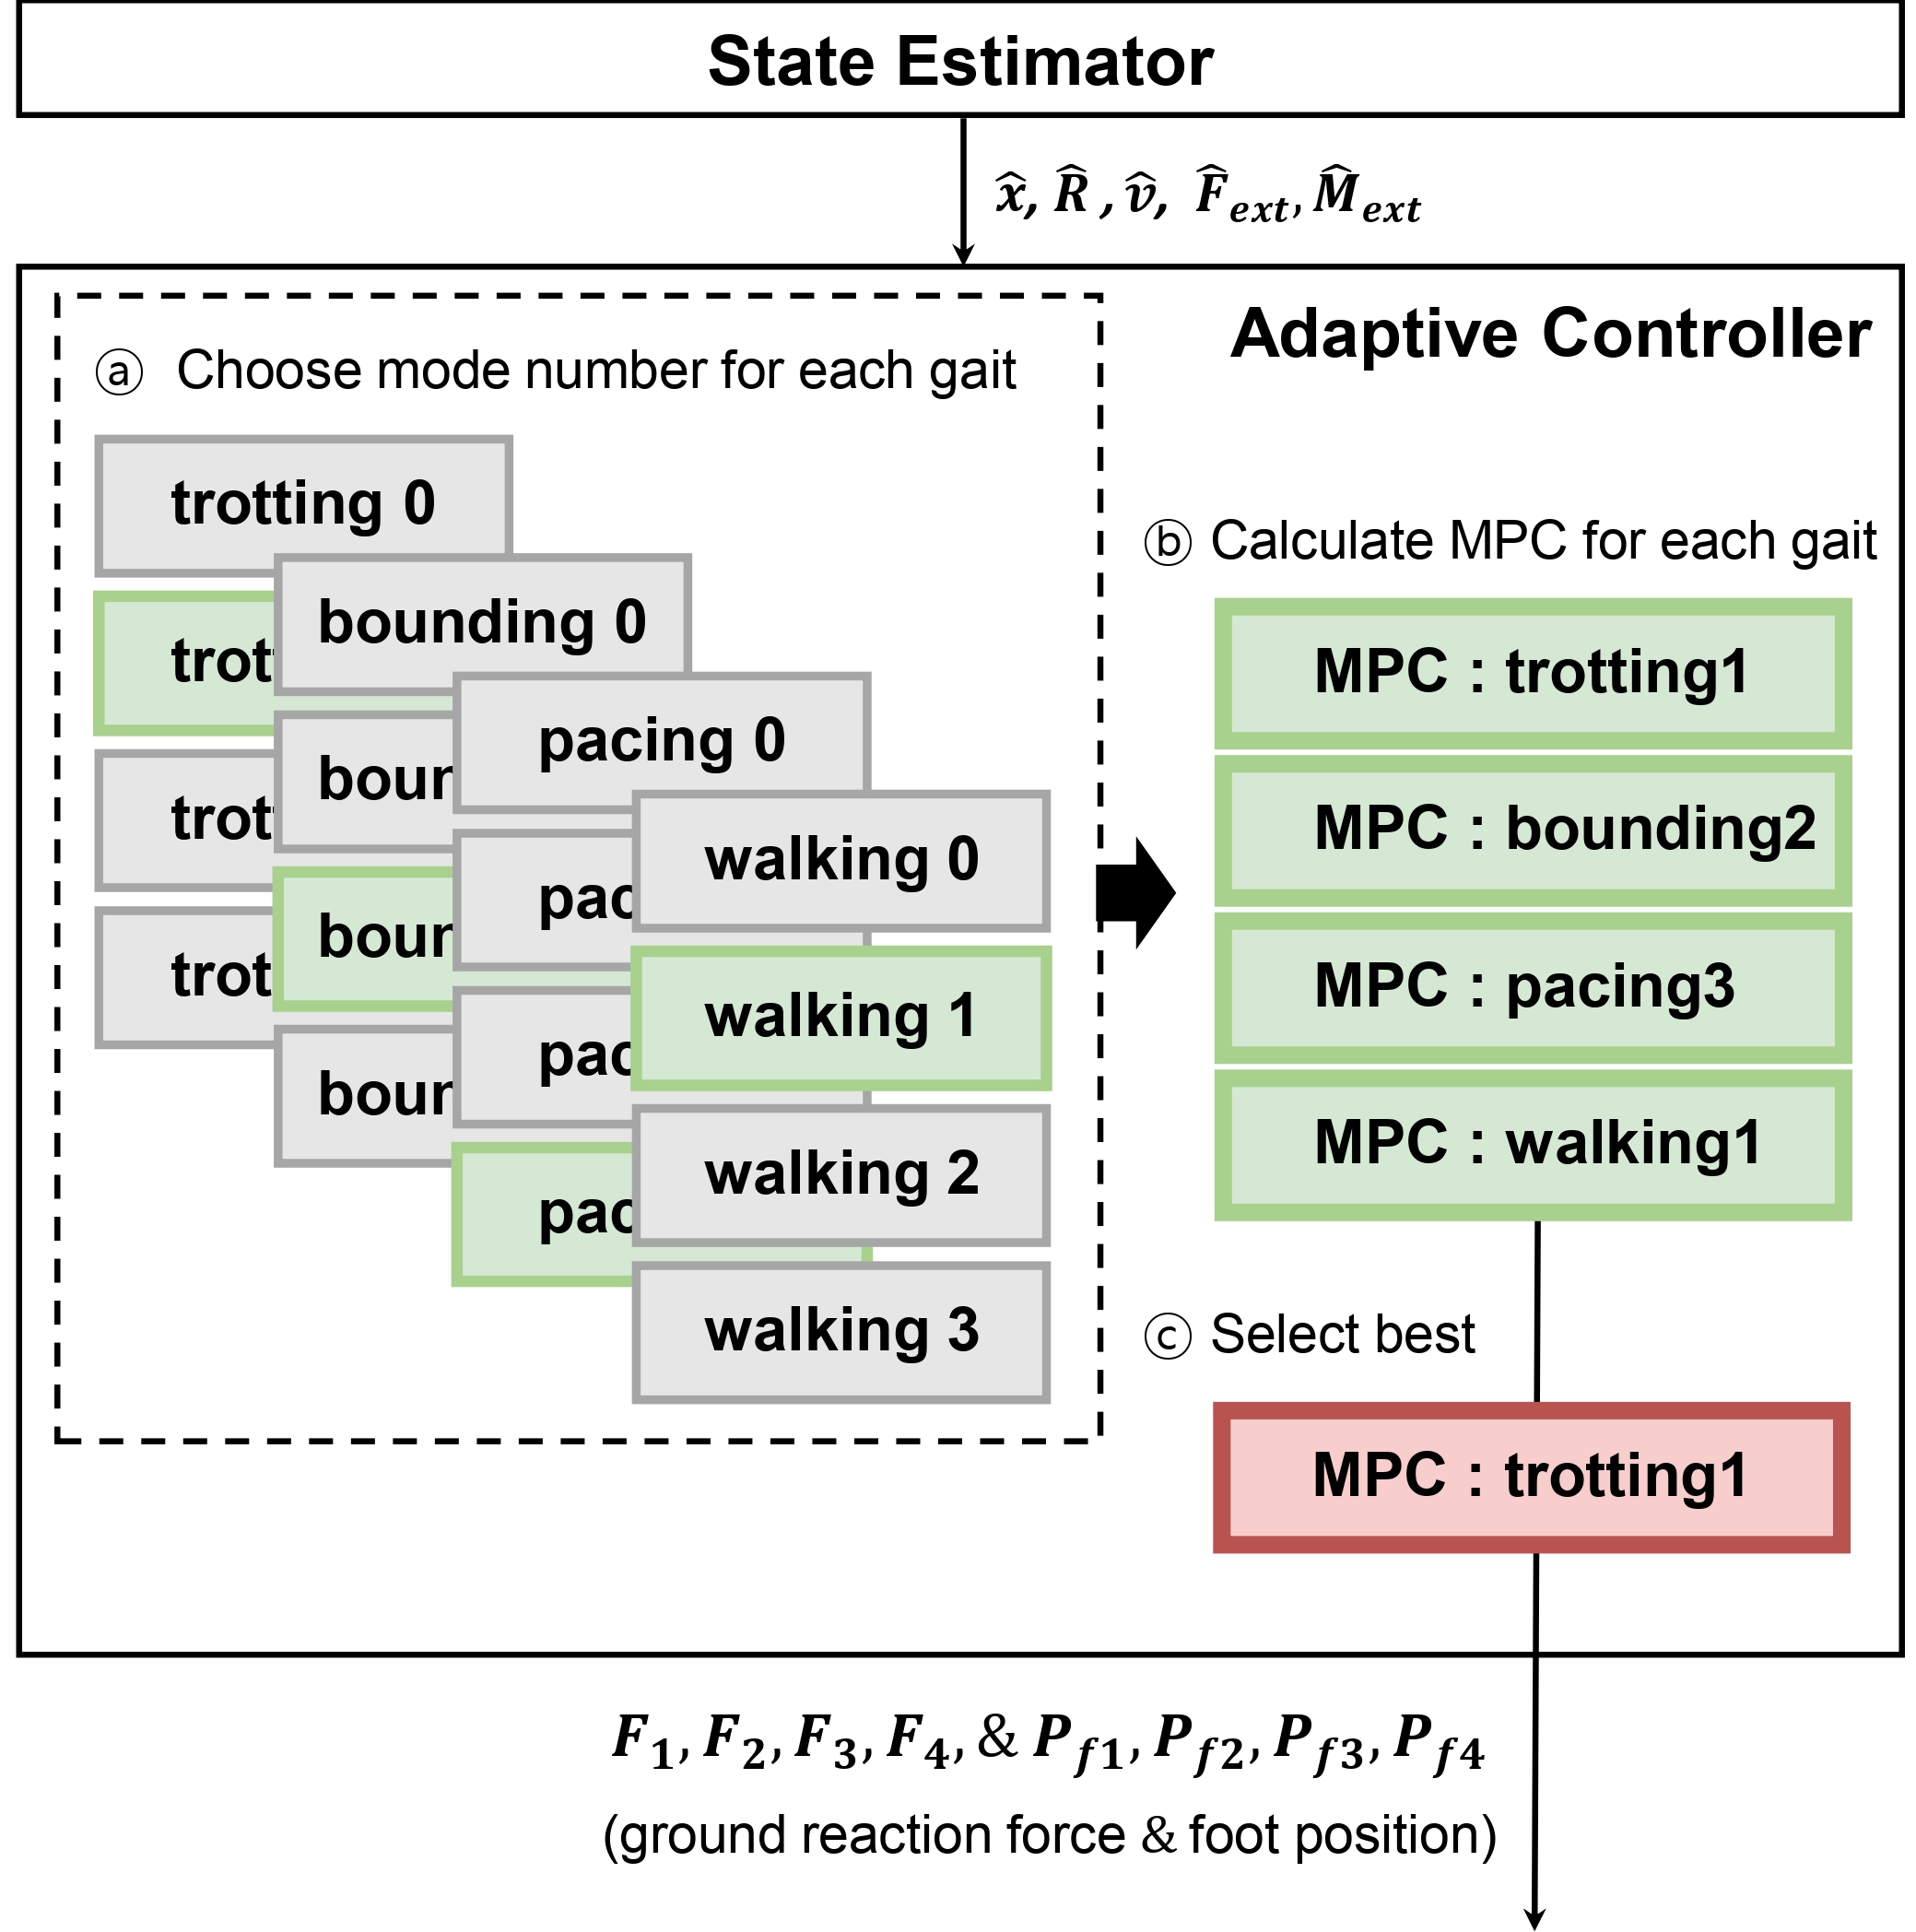 Adaptive Gait Pattern Switching under External Disturbances Using Multi-Modal MPCIn 2025 34th IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), 2025
2024
- Development of remote piping inspection system with dual-mode locomotion quadruped robotIn International Conference on Robot Intelligence Technology and Applications, 2024
Reviews & Others
2026
- Compact Optical Single-axis Joint Torque Sensor Using Redundant Photo-Reflectors and Quadratic-Programming Calibration2026
- Accelerated Generation of Smooth Human-Aware Robot Trajectories via Consistency Distillation from a Diffusion Model2026
2025
- Parameter optimization of optical six-axis force/torque sensor for legged robots2025
2024
-
 이중 볼록 모델 예측 제어를 활용한 사족로봇의 강인한 스윙 다리 위치 계획 알고리즘2024Master’s thesis